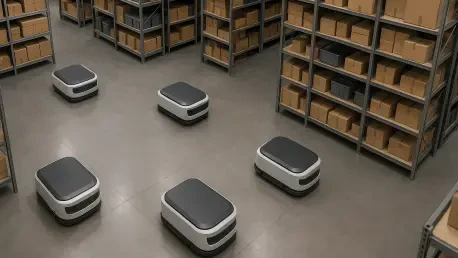
The silent struggle of the modern warehouse is not the lack of machines, but the cacophony of competing software systems that refuse to speak the same language. For years, the robotics industry has grappled with the invisible ceiling of scalability, where adding a new robot brand to a facility meant starting from scratch with integration. This fragmentation has finally met its match with the introduction of OpenRobOps (ORO) by InOrbit AI. As a production-grade, open-source layer, ORO is designed to dismantle the proprietary silos that have long hindered the growth of autonomous mobile robots. By providing a common foundation, this move signals a transition away from custom-built infrastructure and toward a standardized era of fleet management.
The End of the Robotic “Build Trap”
Industrial automation has historically been a prisoner of its own success, where the achievement of building a functional robot was quickly overshadowed by the nightmare of managing it alongside others. While individual machines have become remarkably capable, the logic governing their collective behavior remained fragmented. InOrbit AI identifies this as the “build trap,” a cycle where companies spend eighty percent of their development time on basic plumbing like data pipelines and monitoring dashboards instead of the actual robot application. By introducing OpenRobOps, the company aims to provide a common foundation that treats fleet management as a solved problem rather than a bespoke engineering project.
The release marks a significant departure from the trend of keeping operations software behind a paywall or within a closed ecosystem. In the past, original equipment manufacturers were forced to develop their own telemetry and cloud interfaces, which diverted precious resources away from core innovation. OpenRobOps removes this burden, allowing developers to focus on higher-level intelligence and application-specific tasks. This shift is not just about convenience; it is about the fundamental economic reality of scaling a business in an increasingly competitive technological landscape where speed to market is everything.
Why Standardization: The Next Frontier in Automation
The transition from experimental pilot programs to massive, multi-vendor deployments in 2026 has made the old way of working unsustainable. Modern warehouses and factories are no longer loyal to a single brand, creating a landscape where machines from five different manufacturers must navigate the same narrow aisles. This multi-vendor reality has turned interoperability into a fundamental business requirement. Without a shared framework, these facilities remain stuck in a perpetual state of manual intervention, unable to unlock the true efficiency of a fully autonomous environment.
The missing link has always been a common language, and the adoption of international standards like ISO 21423 is the key to bridging this gap. This standard provides the necessary technical framework for safe and predictable communication between various industrial mobile robots and their respective fleet managers. By implementing these standards, the industry can ensure that a robot from one vendor can report its status, position, and intent to a central system managed by another. This level of transparency is essential for reducing collisions, optimizing traffic flow, and maintaining a safe working environment for human staff.
Deconstructing OpenRobOps: A New Industry Standard
At its core, OpenRobOps serves as the backend infrastructure for the modern robot operations stack, distributed under the permissive Apache 2.0 license. It provides the industry’s first reference implementation of the ISO 21423 standard, ensuring that cross-brand compatibility is no longer a theoretical goal but a functional reality. By moving away from “black box” systems that hide internal data, the platform allows diverse fleets to coexist in shared spaces through collaborative frameworks. This transparency is vital for enterprise-wide analytics and high-level decision-making.
The platform also bridges the gap between the Robot Operating System and commercial cloud operations. Much like how the former standardized hardware drivers and sensor integration for developers, ORO standardizes the telemetry and operational interfaces required for large-scale commercial success. It offers a “ready-to-use” fleet manager that handles the heavy lifting of data exchange, allowing companies to avoid the multi-year development cycles previously required to launch a fleet. This democratization of infrastructure empowers smaller players to compete with industry giants by lowering the technical barrier to entry.
Expert Perspectives: The Shift Toward “Off-the-Shelf” Operations
Industry veterans are increasingly vocal about the need to stop reinventing the wheel regarding fleet management and data handling. Experts like Steve Cousins have noted that the era of building basic robotic infrastructure from scratch is rapidly coming to an end. The consensus among researchers and practitioners is that the value of a robotics company lies in its unique application and AI, not in the basic ability to send a “heartbeat” signal to a cloud server. This shift allows the community to pool resources into a shared, robust infrastructure that benefits everyone.
A recent public demonstration at the Automate event featured ten different companies operating in a single, coordinated environment, providing an undeniable proof of concept for multi-vendor orchestration. This event showcased that when machines speak the same language, the complexity of the environment becomes a non-issue. Furthermore, there is a growing trend toward hybrid environments where fleets must be flexible enough to operate across air-gapped local networks for maximum security, while still integrating with the cloud for global insights. OpenRobOps was designed with this flexibility in mind, catering to both the security-conscious factory and the data-driven logistics hub.
Strategies for Implementing Standardized Fleet Management
Organizations looking to scale can leverage several specific frameworks within OpenRobOps to improve their operational efficiency. One of the most powerful tools is Configuration as Code, which aligns robot management with modern DevOps practices. By using Git workflows to manage telemetry rules and alerts, all updates become version-controlled and repeatable across a global fleet. This approach ensures that every robot, regardless of its location, operates under the same optimized set of rules and safety protocols.
Efficiency is further enhanced through automated remediation and high-throughput telemetry. ORO’s pipelines are engineered to maintain constant diagnostics even in industrial settings with poor network connectivity. When the system detects an anomaly, it can trigger pre-defined recovery protocols to fix the issue without human help. Only the most complex edge cases are escalated to human operators, which significantly reduces the cost of labor per robot. Additionally, built-in adapters for the Robotics Middleware Framework allowed for a seamless sync between physical fleets and digital twins. The deployment of these tools facilitated a more resilient and responsive automation strategy that prepared businesses for the demands of the next several years.
The introduction of OpenRobOps essentially marked the boundary between the experimental era and the industrial era of robotics. It established that the true value of automation existed in the collective performance of a fleet rather than the isolated success of a single machine. By adopting these standards, organizations moved away from siloed development and toward a paradigm where rapid deployment became the norm. This shift allowed technical leaders to refocus their resources on solving high-level business problems while the underlying operational infrastructure functioned as a reliable, standardized utility. Organizations that embraced this open framework realized that collaboration was the most effective way to achieve true autonomy at scale.